

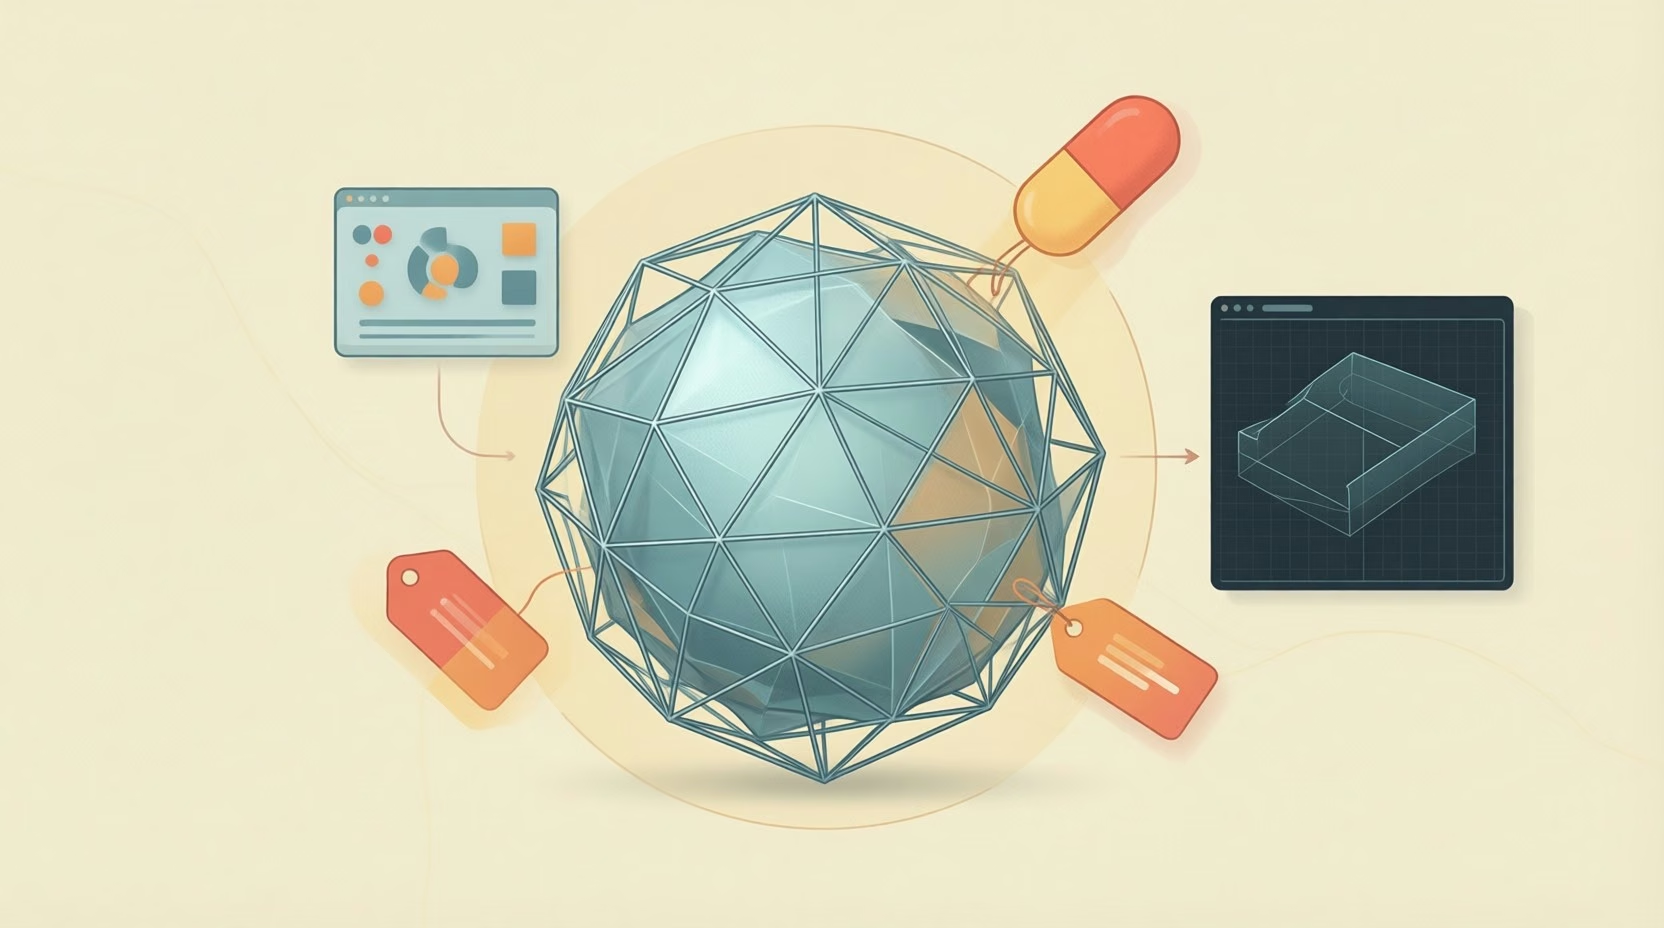
Recognizing an object doesn’t inform a robotic how that object will behave when touched. Take into account a hypothetical activity: pushing a small field to a marked place. Figuring out the field is barely a part of the issue. Coaching additionally wants a illustration of its form, its contact surfaces and its bodily conduct. For bodily AI, the info should assist interplay in addition to notion.
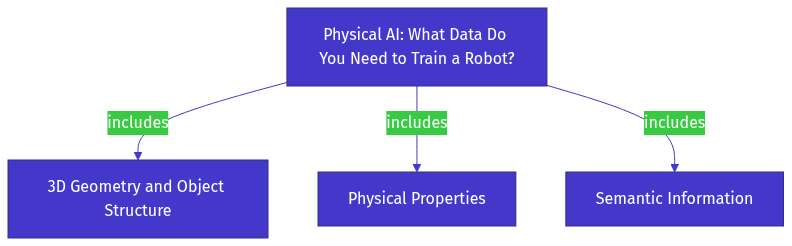
Coaching a robotic for bodily interplay requires 3D geometry, bodily properties and semantic info related to the duty. Simulation additionally wants property that join seen shapes with collision geometry and physics settings. These inputs let a coaching atmosphere symbolize contact and motion, however profitable simulated conduct nonetheless wants validation in opposition to real-world circumstances.
- Geometry describes form and the surfaces used for collision.
- Bodily properties describe mass, inertia and make contact with conduct.
- Semantic labels establish interaction-relevant attributes.
3D Geometry and Object Construction
A visual mannequin and a collision mannequin serve totally different functions. NVIDIA’s Isaac Sim documentation explains {that a} robotic’s URDF visible tag describes a hyperlink’s seen mesh and materials. Its collision tag describes the geometry utilized by the physics engine. For the box-pushing instance, the essential distinction is between what the simulator shows and the geometry it makes use of to calculate contact.
Asset construction additionally impacts how that information may be maintained. NVIDIA describes a layered association that shares geometry, supplies and metadata whereas preserving physics-specific information individually configurable. Collision filtering and PhysX joint settings may be edited with out altering the bottom geometry.
Massive repositories develop the obtainable shapes. The Objaverse 1.0 paper launched greater than 800,000 3D fashions with descriptive captions, tags and animations. That gives substantial geometric and visible selection; the dataset’s measurement alone doesn’t set up {that a} explicit asset accommodates the physics settings a coaching activity wants.
Bodily Properties
Form doesn’t specify mass or inertia. NVIDIA’s URDF rationalization lists each as properties outlined for every robotic hyperlink, alongside visible and collision descriptions. Within the hypothetical pushing activity, geometry identifies the place contact happens; bodily parameters assist decide the ensuing motion.
These parameters could also be generated throughout asset preparation. Physicl says its processing derives friction, mass and collision properties routinely from uncooked inputs. A derived worth is an enter to the simulation, not proof that the simulated object will behave identically to its actual counterpart.
This limitation impacts coaching instantly. A examine of simulation-to-real switch explains that modeling errors can produce methods that achieve a simulator however fail on the bodily system. An agent can be taught the simulator’s explicit conduct, together with its inaccuracies.
Semantic Data
Semantic info information what an asset or attribute means for interplay. Physicl’s instance contains the fields “Graspable: false” and “Interactive: door.” These describe various things: one signifies a graspability attribute, whereas the opposite identifies a door interplay. Neither area provides a mass worth or a collision floor.
For dataset preparation, the sensible query is whether or not a label expresses the interplay the duty wants. A door label doesn’t itself specify how the door strikes. Semantic info provides that means; geometry and bodily properties provide separate components of the simulation illustration.
Utilizing Simulation Knowledge to Prepare Bodily AI
Simulation begins with property the atmosphere can use. Isaac Sim accepts robotic property arriving as meshes, STEP information, URDF or MuJoCo XML Format information and imports them into OpenUSD utilizing USD Asset Construction 3.0. Importing establishes the asset illustration earlier than inspection, filtering or tuning; it doesn’t set up that each bodily parameter is correct.
Simulation gives considerable coaching information and alleviates sure security issues, in response to the dynamics-randomization examine. The researchers diversified simulator dynamics throughout coaching so the discovered insurance policies might adapt to totally different bodily conduct.
They examined the method on a robotic-arm object-pushing activity. Insurance policies educated solely in simulation maintained comparable efficiency on an actual robotic, transferring an object to a goal from random preliminary configurations. That end result helps dynamics randomization for the demonstrated activity. It doesn’t set up that any imported asset, or any robotic activity, will switch efficiently with out bodily testing.
Why Simulation-Prepared 3D Knowledge Issues
Not each 3D mannequin is helpful for coaching robots. Massive collections like Objaverse provide many shapes and visuals however typically lack constant bodily properties wanted for simulation. To fill this hole, some corporations, comparable to Physicl, present 3D property that embody physics information and are prepared for simulation. These property embody particulars like mass, collision meshes, friction values, and semantic labels for graspability and interactivity. This additional info helps simulated objects behave extra like actual ones, giving robots higher environments to be taught bodily duties.
Incessantly Requested Questions
Is a visual 3D mesh sufficient for physics simulation?
No. NVIDIA’s URDF documentation distinguishes seen meshes from collision geometry and individually defines mass and inertia for robotic hyperlinks. Look alone doesn’t specify these properties.
Can a robotic be taught completely in simulation?
It could for some demonstrated duties. The cited object-pushing examine transferred simulation-trained insurance policies to an actual robotic utilizing randomized dynamics. Its end result doesn’t assure switch throughout different duties.
Match the Knowledge to the Interplay
Begin with one outlined motion, comparable to pushing the field. Examine that the asset provides usable contact geometry, related bodily parameters and significant interplay labels. Then consider whether or not the simulated conduct transfers to the bodily activity. A whole-looking mannequin and a profitable coaching run reply totally different questions; neither alone establishes real-world efficiency.